The history of Artificial Intelligence (AI) can be traced back to antiquity, where the concept of intelligent beings and automatons appeared in mythological tales from various ancient civilizations. However, the formalization of AI as a field of study began in the 20th century.
Mechanical automata developed over many centuries. Renaissance examples include a 16th-century clockwork monk traditionally associated with Juanelo Turriano. Such mechanisms imitated movement through mechanical sequences; they did not demonstrate machine intelligence in the modern sense.
During the Age of Enlightenment in the 17th and 18th centuries, thinkers explored the philosophical aspects of human intelligence and pondered the potential for machines to simulate human thought processes.
In the 19th century, the groundwork for computing was laid by inventors like Charles Babbage, who designed mechanical computers, and Ada Lovelace, who delved into programming and algorithms.
The term “artificial intelligence” appeared in the Dartmouth research proposal of 1955. The Dartmouth Workshop in 1956 is considered the birth of AI as an academic discipline, where researchers gathered to explore the potential of creating intelligent machines.
During the 1950s and 1960s, early AI research focused on symbolic reasoning and problem-solving. The development of early AI programs like the Logic Theorist and the General Problem Solver showcased the potential of AI applications.
The 1970s and 1980s saw the rise of expert systems, which represented knowledge in rule-based systems to solve specific problems. Robotics also advanced during this period, building on earlier industrial applications such as Unimate at General Motors in 1961.
In the 1990s and 2000s, AI research shifted towards machine learning techniques, including neural networks and statistical approaches. The development of the World Wide Web provided vast amounts of data, enabling AI systems to learn from and improve their performance.
The 2010s witnessed significant breakthroughs in AI, primarily driven by deep learning techniques. These advancements led to remarkable achievements in image recognition, speech synthesis, and natural language processing.
As of 2023, AI continues to rapidly evolve. Research is ongoing in areas like reinforcement learning, generative models, and explainable AI. AI applications have expanded into various industries, including healthcare, finance, transportation, and entertainment, transforming how we live and work.
However, with the increasing integration of AI in society, ethical considerations and responsible AI practices have become critical concerns, ensuring that AI technologies are developed and deployed in a manner that benefits humanity while mitigating potential risks. The history of AI reflects a journey of continuous innovation, challenges, and ethical reflections, shaping the landscape of modern technology and its impact on human life.
The following selective timeline runs from ancient stories of artificial beings to developments in 2023. Myths, philosophical ideas, mechanical automation and modern AI are different kinds of milestone. Dates identify the events or periods described; inclusion does not establish priority over every earlier contribution.
| Date or period | Milestone and context |
|---|---|
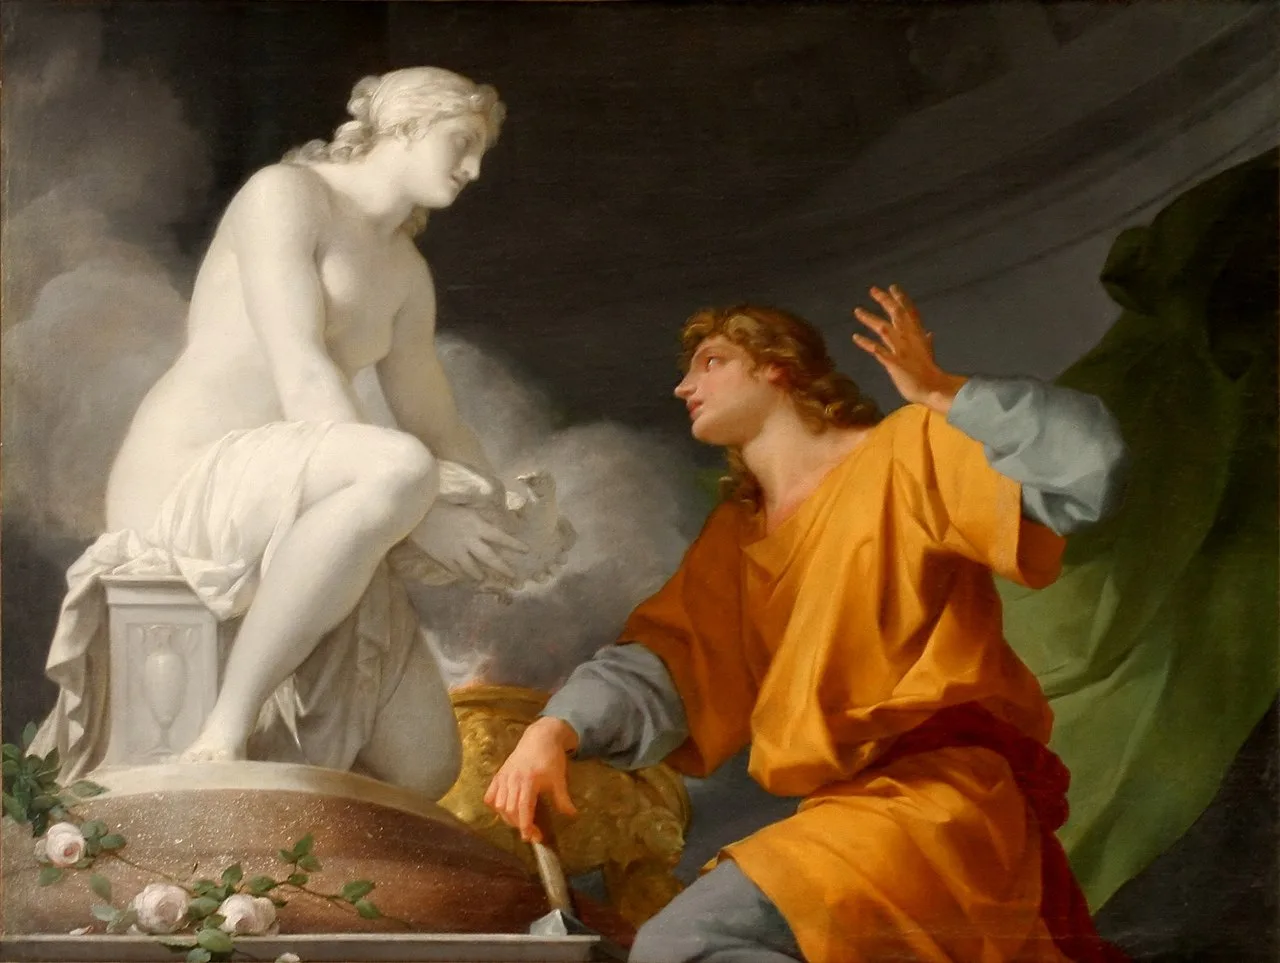
| Antiquity | Greek myths of Hephaestus and Pygmalion incorporated the idea of intelligent automata (such as Talos) and artificial beings (such as Galatea and Pandora) |
| Antiquity | Ancient religious and philosophical traditions attributed life, wisdom or agency to statues and artificial beings. These accounts belong to the history of beliefs about artificial life, not evidence of machines possessing emotion. |
| Ancient Chinese legend | The Liezi recounts an artificer, Yan Shi, presenting a human-like automaton to King Mu of Zhou. The setting is traditionally placed in the 10th century BC; the story is not a verified record of a machine built at that date. |
| 4th century BC | Aristotle developed syllogistic reasoning in the works later collected as the Organon, an influential contribution to formal logic. |
| 3rd century BC | Ctesibius developed water-clock mechanisms. Regulation of water flow provides an early example of feedback in a mechanical device. |
| 1st century AD | Hero of Alexandria described automata and an automatic theatre whose movements followed a mechanically arranged sequence. Such devices belong to the history of automation, rather than machine learning. |
| 3rd century AD | Porphyry wrote the Isagoge, an introduction to categories and logical classification. |
| Medieval alchemical tradition | Texts associated with Jabir ibn Hayyan discuss takwin, or the artificial generation of life. These are alchemical ideas, not demonstrated laboratory creation of human life. |
| 9th century | The Banu Musa brothers described ingenious mechanical devices and automatic musical mechanisms. These illustrate programmed sequences in automata; they should not be equated with modern stored-program computers. |
| 1206 | Al-Jazari described water-powered automata and musical mechanisms in his book on mechanical devices. |
| Late 13th century | Ramon Llull developed combinatorial methods, including diagrams and rotating figures, to organize concepts and arguments. His Art became part of the later history of attempts to mechanize reasoning. |
| 16th century | The homunculus appears in alchemical writing associated with Paracelsus. It represents speculation about artificial life, not a demonstrated artificial human. |
| Prague golem legend | Later stories associate Rabbi Judah Loew ben Bezalel with a clay figure brought to life. This is a cultural and religious legend, not a documented engineering invention in 1580. |
| 1620 | Francis Bacon developed empirical theory of knowledge and introduced inductive logic in his work Novum Organum, a play on Aristotle's title Organon. |
| 1623 | Wilhelm Schickard described a calculating clock in correspondence with Johannes Kepler. It is an early example in the history of mechanical calculation. |
| 1642 | Blaise Pascal began developing his mechanical calculator, the Pascaline, for arithmetic operations. |
| 1651 | Thomas Hobbes published Leviathan, including a description of reasoning in terms of calculation. The publication belongs to the philosophical background of mechanized thought. NYPL edition record. |
| Late 17th–early 18th century | Gottfried Wilhelm Leibniz developed the Stepped Reckoner and explored a universal calculus of reasoning. His work on binary arithmetic should be distinguished from the decimal mechanism of the calculator. |
| 17th century | The development of differential calculus provided the chain rule. Much later, efficient applications of that rule became central to computing gradients in neural-network training. |
| 1726 | Jonathan Swift published Gulliver’s Travels. Its fictional Engine on Laputa satirizes the idea that mechanical combinations of words could generate learned works without understanding. |
| 18th century | Julien Offray de La Mettrie published L’Homme Machine, advancing a materialist account of human thought. |
| 1763 | Thomas Bayes's work An Essay towards solving a Problem in the Doctrine of Chances, published two years after his death, laid the foundations of Bayes' theorem. |
| 1769 | Wolfgang von Kempelen built and toured with his chess-playing automaton, The Turk, which Kempelen claimed could defeat human players. The Turk was later shown to be a hoax, involving a human chess player. |
| Late 18th–early 19th century | Work by Gauss and Legendre on least squares contributed to mathematical methods now widely used in statistical learning. Modern linear models have connections to this tradition, although calling those historical methods artificial neural networks is retrospective terminology. |
| Early 19th century | Joseph Marie Jacquard developed a loom mechanism using punched cards to control weaving patterns, building on earlier textile mechanisms. The replaceable cards are an important example in the history of programmable machinery. |
| 1805 | Adrien-Marie Legendre describes the "méthode des moindres carrés", known in English as the least squares method. The least squares method is used widely in data fitting. |
| 1818 | Mary Shelley published the story of Frankenstein; or the Modern Prometheus, a fictional consideration of the ethics of creating sentient beings. |
| 1820s–1840s | Charles Babbage developed designs for mechanical calculating engines. Ada Lovelace’s 1843 notes on the Analytical Engine discussed its possible uses and included a procedure for calculating Bernoulli numbers. Their contributions should not be presented as a joint collaboration continuing to 1859. |
| 1837 | Bernard Bolzano published work on logic and the theory of science, contributing to later discussions of meaning and formal reasoning. |
| 1854 | George Boole set out to "investigate the fundamental laws of those operations of the mind by which reasoning is performed, to give expression to them in the symbolic language of a calculus", inventing Boolean algebra. |
| 1863 | Samuel Butler suggested that Darwinian evolution also applies to machines, and speculates that they will one day become conscious and eventually supplant humanity. |
| 1910-1913 | Bertrand Russell and Alfred North Whitehead published Principia Mathematica, which revolutionized formal logic. |
| 1912–1914 | Leonardo Torres Quevedo developed El Ajedrecista, an electromechanical automaton for a restricted chess endgame. His Essays on Automatics discussed the capabilities of automatic machines. |
| 1920s | Karel Čapek’s play R.U.R. introduced the word robot and reached the London stage in 1923. Its artificial workers belong to the cultural history surrounding later robotics. |
| 1920–1925 | Wilhelm Lenz and Ernst Ising developed the Ising model in statistical physics. Its interacting units later provided useful connections to models of neural computation; it was not originally designed as an AI system. |
| 1920s–1940s | Ludwig Wittgenstein’s early and later philosophy influenced debates about logic, language and meaning. His later emphasis on language in use should not be described as a technical proof that symbolic logic or artificial intelligence is incoherent. |
| 1931 | Kurt Gödel established incompleteness results for sufficiently expressive, effectively axiomatized formal systems under appropriate consistency conditions. These results place limits on formal proof systems; they do not by themselves settle whether machines can think. |
| 1930s | Alonzo Church developed lambda calculus and established an undecidability result for the Entscheidungsproblem in 1936. This work contributed to the mathematical foundations of computation. |
| 1936 | Konrad Zuse filed his patent application for a program-controlled computer. |
| 1936–1937 | Alan Turing’s On Computable Numbers introduced an abstract model of computation and addressed the limits of mechanical decision procedures. It is a foundation of computability theory. |
| 1940 | Edward Condon displayed Nimatron, a digital machine that played Nim perfectly. |
| 1941 | Konrad Zuse completed the Z3, an electromechanical, program-controlled calculating machine. |
| 1943 | Warren McCulloch and Walter Pitts published A Logical Calculus of the Ideas Immanent in Nervous Activity, describing a mathematical model of neural activity relevant to later neural-network research. |
| 1943 | Arturo Rosenblueth, Norbert Wiener and Julian Bigelow published Behavior, Purpose and Teleology. Wiener’s book Cybernetics followed in 1948; the two publications should not be conflated. |
| 1944 | John von Neumann and Oskar Morgenstern published the book Theory of Games and Economic Behavior. Game theory later became important to decision-making and multi-agent research. |
| 1945 | Vannevar Bush published "As We May Think" (The Atlantic Monthly, July 1945) a prescient vision of the future in which computers assist humans in many activities. |
| 1948 | Norbert Wiener published Cybernetics, developing a framework for studying control and communication in animals and machines. |
| 1950 | Alan Turing proposes the Turing test as a measure of machine intelligence. |
| 1950 | Claude Shannon published a detailed analysis of chess playing as search. |
| 1950 | Isaac Asimov’s collection I, Robot explored fictional robots and the consequences of their programmed rules. The Three Laws had appeared earlier, in the 1942 story Runaround. |
| 1951 | Christopher Strachey developed a draughts-playing program and Dietrich Prinz a restricted chess program for early computers, including the Ferranti Mark 1. These were early demonstrations of computer game playing. |
| 1952–1962 | Arthur Samuel (IBM) wrote the first game-playing program, for checkers (draughts), to achieve sufficient skill to challenge a respectable amateur. His first checkers-playing program was written in 1952, and in 1955 he created a version that learned to play. |
| 1956 | The Dartmouth summer research project brought together researchers interested in artificial intelligence. The phrase already appeared in the proposal dated 31 August 1955 by John McCarthy, Marvin Minsky, Nathaniel Rochester and Claude Shannon. 1955 proposal. |
| 1956 | Allen Newell, J. C. Shaw and Herbert Simon developed the Logic Theorist, demonstrating automated theorem proving on propositions from Principia Mathematica. This was an influential early symbolic AI programme. |
| 1950s | The success of symbolic programmes encouraged debate about whether computation could explain human reasoning. Philosophical claims about minds should be distinguished from the specific tasks those programmes demonstrated. |
| 1958 | John McCarthy (Massachusetts Institute of Technology or MIT) invented the Lisp programming language. |
| 1958 | Herbert Gelernter and Nathan Rochester (IBM) described a theorem prover in geometry that exploits a semantic model of the domain in the form of diagrams of "typical" cases. |
| 1958 | Teddington Conference on the Mechanization of Thought Processes was held in the UK and among the papers presented were John McCarthy's "Programs with Common Sense", Oliver Selfridge's "Pandemonium", and Marvin Minsky's "Some Methods of Heuristic Programming and Artificial Intelligence". |
| 1959 | The General Problem Solver (GPS) was created by Newell, Shaw and Simon while at CMU. |
| 1959 | John McCarthy and Marvin Minsky founded the MIT AI Lab. |
| 1960s | Ray Solomonoff lays the foundations of a mathematical theory of AI, introducing universal Bayesian methods for inductive inference and prediction. |
| 1960 | "Man-Computer Symbiosis" by J.C.R. Licklider. |
| 1961 | James Slagle (PhD dissertation, MIT) wrote (in Lisp) an early symbolic integration program, SAINT, which solved calculus problems at the college freshman level. |
| 1961 | In Minds, Machines and Gödel, John Lucas used incompleteness to argue against a computational account of the mind. This was a philosophical argument subject to continuing criticism, not a proof accepted as ruling out machine intelligence. |
| 1961 | Unimation's industrial robot Unimate worked on a General Motors automobile assembly line. Computer History Museum. |
| 1963 | Thomas Evans' program, ANALOGY, written as part of his PhD work at MIT, demonstrated that computers can solve the same analogy problems as are given on IQ tests. |
| 1963 | Edward Feigenbaum and Julian Feldman published Computers and Thought, an early collection of articles about artificial intelligence. |
| 1963 | Leonard Uhr and Charles Vossler published "A Pattern Recognition Program That Generates, Evaluates, and Adjusts Its Own Operators", which described one of the first machine learning programs that could adaptively acquire and modify features and thereby overcome the limitations of simple perceptrons of Rosenblatt. |
| 1964 | Daniel Bobrow’s STUDENT programme processed a restricted class of algebra word problems. The demonstration concerned a constrained language and task, not unrestricted understanding of natural language. |
| 1964 | Bertram Raphael's MIT dissertation on the SIR program demonstrates the power of a logical representation of knowledge for question-answering systems. |
| 1960s | Alexey Ivakhnenko and Valentin Lapa developed methods for constructing and training multilayer models, contributing to the history of deep learning. |
| 1965 | Lotfi Zadeh at U.C. Berkeley publishes his first paper introducing fuzzy logic, "Fuzzy Sets" (Information and Control 8: 338–353). |
| 1965 | J. Alan Robinson invented a mechanical proof procedure, the Resolution Method, which allowed programs to work efficiently with formal logic as a representation language. |
| 1966 | Joseph Weizenbaum published his work on ELIZA. Its DOCTOR script used pattern matching and text substitutions to imitate a therapeutic conversation within clear limitations. Computer History Museum. |
| 1965 | Edward Feigenbaum initiated Dendral, a ten-year effort to develop software to deduce the molecular structure of organic compounds using scientific instrument data. It was the first expert system. |
| 1966 | Ross Quillian (PhD dissertation, Carnegie Inst. of Technology, now CMU) demonstrated semantic nets. |
| 1966 | Machine Intelligence workshop at Edinburgh – the first of an influential annual series organized by Donald Michie and others. |
| 1966 | The ALPAC report criticized the progress and economics of machine translation, influencing US research funding. Its consequences should not be generalized to the disappearance of all natural-language research. |
| 1966 | Dendral program (Edward Feigenbaum, Joshua Lederberg, Bruce Buchanan, Georgia Sutherland at Stanford University) demonstrated to interpret mass spectra on organic chemical compounds. An early knowledge-based programme for scientific reasoning. |
| 1967 | Shun’ichi Amari investigated learning in multilayer networks, including gradient-based adjustment of parameters. These experiments form part of the longer development of neural-network training methods. |
| 1968 | Joel Moses (PhD work at MIT) demonstrated the power of symbolic reasoning for integration problems in the Macsyma program. An early knowledge-based programme in mathematics. |
| 1968 | Richard Greenblatt (programmer) at MIT built a knowledge-based chess-playing program, MacHack, that was good enough to achieve a class-C rating in tournament play. |
| 1968 | Wallace and Boulton's program, Snob (Comp.J. 11(2) 1968), for unsupervised classification (clustering) uses the Bayesian Minimum Message Length criterion, a mathematical realisation of Occam's razor. |
| Late 1960s–early 1970s | SRI’s Shakey combined perception, planning and movement in a mobile robot operating in a constrained environment. |
| 1969 | Roger Schank (Stanford) defined conceptual dependency model for natural-language understanding. Later developed (in PhD dissertations at Yale University) for use in story understanding by Robert Wilensky and Wendy Lehnert, and for use in understanding memory by Janet Kolodner. |
| 1969 | Yorick Wilks (Stanford) developed the semantic coherence view of language called Preference Semantics, embodied in a semantics-driven machine translation programme, and the basis of many PhD dissertations since such as Bran Boguraev and David Carter at Cambridge. |
| 1969 | First International Joint Conference on Artificial Intelligence (IJCAI) held at Stanford. |
| 1969 | Marvin Minsky and Seymour Papert published Perceptrons, analyzing limitations of particular perceptron architectures. The relationship between this work, research funding and later AI winters is more complex than a single cause; other neural and symbolic research continued. |
| 1969 | McCarthy and Hayes started the discussion about the frame problem with their essay, "Some Philosophical Problems from the Standpoint of Artificial Intelligence". |
| 1970 | Seppo Linnainmaa developed an efficient reverse-mode method for automatic differentiation. Reverse-mode differentiation underlies the gradient computation used in backpropagation, whose application to neural-network learning developed through subsequent work. |
| 1970 | Jaime Carbonell (Sr.) developed SCHOLAR, an interactive program for computer assisted instruction based on semantic nets as the representation of knowledge. |
| 1970 | Bill Woods described Augmented Transition Networks (ATN's) as a representation for natural language understanding. |
| 1970 | Patrick Winston's PhD program, ARCH, at MIT learned concepts from examples in the world of children's blocks. |
| 1971 | Terry Winograd’s thesis described SHRDLU, which interpreted commands and answered questions in a restricted, simulated blocks world. Its capabilities depended on that carefully defined environment. Computer History Museum. |
| 1971 | Work on the Boyer-Moore theorem prover started in Edinburgh. |
| 1972 | Prolog programming language developed by Alain Colmerauer. |
| 1972 | Earl Sacerdoti developed one of the first hierarchical planning programs, ABSTRIPS. |
| 1973 | The Assembly Robotics Group at University of Edinburgh builds Freddy Robot, capable of using visual perception to locate and assemble models. (See Edinburgh Freddy Assembly Robot: a versatile computer-controlled assembly system.) |
| 1973 | The Lighthill report gave a critical assessment of AI research in Britain and influenced subsequent funding decisions. |
| 1974 | Ted Shortliffe's PhD dissertation on the MYCIN program (Stanford) demonstrated a very practical rule-based approach to medical diagnoses, even in the presence of uncertainty. While it borrowed from DENDRAL, its own contributions strongly influenced the future of expert system development, especially commercial systems. |
| 1975 | Earl Sacerdoti developed techniques of partial-order planning in his NOAH system, replacing the previous paradigm of search among state space descriptions. NOAH was applied at SRI International to interactively diagnose and repair electromechanical systems. |
| 1975 | Austin Tate developed the Nonlin hierarchical planning system able to search a space of partial plans characterised as alternative approaches to the underlying goal structure of the plan. |
| 1975 | Marvin Minsky published his widely read and influential article on Frames as a representation of knowledge, in which many ideas about schemas and semantic links are brought together. |
| 1975 | Meta-DENDRAL generated rules for interpreting mass spectra, with results reported in the scientific literature. It is an early example of a learning system contributing to scientific analysis. |
| 1970s | David Marr and colleagues at MIT developed theories of visual processing, including the primal sketch. |
| 1976 | Douglas Lenat's AM program (Stanford PhD dissertation) demonstrated the discovery model (loosely guided search for interesting conjectures). |
| 1976 | Randall Davis demonstrated the power of meta-level reasoning in his PhD dissertation at Stanford. |
| 1978 | Tom Mitchell, at Stanford, invented the concept of Version spaces for describing the search space of a concept formation program. |
| 1978 | Herbert A. Simon wins the Nobel Prize in Economics for his theory of bounded rationality, one of the cornerstones of AI known as "satisficing". |
| 1978 | The MOLGEN program, written at Stanford by Mark Stefik and Peter Friedland, demonstrated that an object-oriented programming representation of knowledge can be used to plan gene-cloning experiments. |
| 1979 | Bill VanMelle's PhD dissertation at Stanford demonstrated the generality of MYCIN's representation of knowledge and style of reasoning in his EMYCIN program, the model for many commercial expert system "shells". |
| 1979 | Jack Myers and Harry Pople at University of Pittsburgh developed INTERNIST, a knowledge-based medical diagnosis program based on Dr. Myers' clinical knowledge. |
| 1979 | Cordell Green, David Barstow, Elaine Kant and others at Stanford demonstrated the CHI system for automatic programming. |
| 1979 | Hans Moravec’s Stanford Cart navigated through a room containing obstacles under computer control, an important autonomous-navigation demonstration. |
| 1979 | BKG, a backgammon program written by Hans Berliner at CMU, defeats the reigning world champion (in part via luck). |
| 1979 | Drew McDermott and Jon Doyle at MIT, and John McCarthy at Stanford begin publishing work on non-monotonic logics and formal aspects of truth maintenance. |
| 1980 | Lisp machines developed and marketed. First expert system shells and commercial applications. |
| 1980 | First National Conference of the American Association for Artificial Intelligence (AAAI) held at Stanford. |
| 1981 | Danny Hillis designs the connection machine, which utilizes parallel computing to bring new power to AI, and to computation in general. (Later founds Thinking Machines Corporation) |
| 1982 | The Fifth Generation Computer Systems project (FGCS), an initiative by Japan's Ministry of International Trade and Industry, begun in 1982, to create a "fifth generation computer" (see history of computing hardware) which was supposed to perform much calculation utilizing massive parallelism. |
| 1983 | John Laird and Paul Rosenbloom, working with Allen Newell, complete CMU dissertations on Soar (program). |
| 1983 | James F. Allen invents the Interval Calculus, the first widely used formalization of temporal events. |
| 1985 | The autonomous drawing program, AARON, created by Harold Cohen, is demonstrated at the AAAI National Conference (based on more than a decade of work, and with subsequent work showing major developments). |
| 1980s | Ernst Dickmanns and colleagues developed vision-based autonomous vehicle demonstrations. Their results were achieved under specified road and supervision conditions. |
| 1986 | Barbara Grosz and Candace Sidner published an influential computational account of discourse structure. |
| 1986 | Marvin Minsky published The Society of Mind, presenting intelligence as the interaction of many simpler processes or agents. MIT bibliography. |
| 1987 | Around the same time, Rodney Brooks introduced the subsumption architecture and behavior-based robotics as a more minimalist modular model of natural intelligence; Nouvelle AI. |
| 1987 | Alacrity was a commercial expert-system application for strategic and managerial advice, associated with Alistair Davidson, Mary Chung and Paul Tarvydas. Its rule-based approach illustrates attempts to apply expert systems to business decisions. |
| 1989 | The development of metal–oxide–semiconductor (MOS) Very Large Scale Integration (VLSI), in the form of complementary MOS (CMOS) technology, enabled the development of practical artificial neural network (ANN) technology in the 1980s. A landmark publication in the field was the 1989 book Analog VLSI Implementation of Neural Systems by Carver A. Mead and Mohammed Ismail |
| 1989 | Dean Pomerleau at CMU creates ALVINN (An Autonomous Land Vehicle in a Neural Network). |
| 1991 | The Dynamic Analysis and Replanning Tool (DART) supported logistics planning during the Gulf War. Its use is an example of operational planning software; broad claims that it repaid all previous AI research investment require separate financial evidence. |
| 1992 | Carol Stoker and NASA Ames robotics team explore marine life in Antarctica with an undersea robot Telepresence ROV operated from the ice near McMurdo Bay, Antarctica and remotely via satellite link from Moffett Field, California. |
| 1993 | Ian Horswill developed Polly, a mobile robot that used visual information for navigation in a constrained environment. |
| 1993 | Rodney Brooks, Lynn Andrea Stein and Cynthia Breazeal started the widely publicized MIT Cog project with numerous collaborators, in an attempt to build a humanoid robot child in just five years. |
| 1993 | ISX’s work on DART attracted attention as an application of AI planning to logistics. Its deployment should be distinguished from unverified estimates of a return on decades of government research spending. |
| 1994 | Lotfi Zadeh at U.C. Berkeley creates "soft computing" and builds a world network of research with a fusion of neural science and neural net systems, fuzzy set theory and fuzzy systems, evolutionary algorithms, genetic programming, and chaos theory and chaotic systems ("Fuzzy Logic, Neural Networks, and Soft Computing", Communications of the ACM, March 1994, Vol. 37 No. 3, pages 77–84). |
| 1994 | The VaMP and VITA-2 vehicles associated with Ernst Dickmanns and Daimler-Benz demonstrated automated driving functions on highways, including lane following and lane changes under the conditions of the trials. |
| 1994 | Chinook competed at the highest level of English draughts. Marion Tinsley withdrew from their match because of illness; this should not be described as a straightforward match victory over him. |
| 1994 | Cindy Mason at NASA organizes the First AAAI Workshop on AI and the Environment. |
| 1995 | Cindy Mason at NASA organizes the First International IJCAI Workshop on AI and the Environment. |
| 1995 | The No Hands Across America demonstration used computer-controlled steering for most of a cross-country journey. A human driver controlled throttle and brakes, so the demonstration was not fully autonomous driving. |
| 1995 | A vehicle from Ernst Dickmanns’ programme demonstrated automated driving on a journey between Munich and Copenhagen, with human intervention when required. The demonstration’s supervision and operating conditions matter when interpreting its capability. |
| 1996 | Steve Grand, roboticist and computer scientist, develops and releases Creatures, a popular simulation of artificial life-forms with simulated biochemistry, neurology with learning algorithms and inheritable digital DNA. |
| 1997 | The Deep Blue chess machine (IBM) defeats the (then) world chess champion, Garry Kasparov. |
| 1997 | The first RoboCup competition brought together robot soccer teams, creating a continuing benchmark for multi-agent robotics. |
| 1997 | Computer Othello program Logistello defeated the world champion Takeshi Murakami with a score of 6–0. |
| 1997 | Sepp Hochreiter and Jürgen Schmidhuber published Long Short-Term Memory in Neural Computation. LSTM became an influential architecture for learning from sequences. |
| 1998 | Tiger Electronics released Furby, an interactive consumer toy. Its scripted and adaptive behaviours should not be confused with general intelligence. |
| 1998 | Tim Berners-Lee published his Semantic Web Road map paper. |
| 1998 | Ulises Cortés and Miquel Sànchez-Marrè organize the first Environment and AI Workshop in Europe ECAI, "Binding Environmental Sciences and Artificial Intelligence". |
| 1998 | Leslie Kaelbling, Michael Littman and Anthony Cassandra published an influential treatment of planning and acting in partially observable environments, helping develop the use of POMDPs in AI. |
| 1999 | Sony introduced AIBO, a robotic pet combining sensors, movement and interactive behaviour. |
| 2000 | Interactive robopets ("smart toys") become commercially available, realizing the vision of the 18th century novelty toy makers. |
| 2000 | Cynthia Breazeal at MIT publishes her dissertation on Sociable machines, describing Kismet (robot), with a face that expresses emotions. |
| 2000 | The Nomad robot explores remote regions of Antarctica looking for meteorite samples. |
| 2002 | iRobot's Roomba autonomously vacuums the floor while navigating and avoiding obstacles. |
| 2004 | OWL Web Ontology Language W3C Recommendation (10 February 2004). |
| 2004 | DARPA introduces the DARPA Grand Challenge requiring competitors to produce autonomous vehicles for prize money. |
| 2004 | NASA's robotic exploration rovers Spirit and Opportunity autonomously navigate the surface of Mars. |
| 2005 | Honda's ASIMO robot, an artificially intelligent humanoid robot, is able to walk as fast as a human, delivering trays to customers in restaurant settings. |
| 2005 | Recommendation technology based on tracking web activity or media usage brings AI to marketing. See TiVo Suggestions. |
| 2005 | The Blue Brain project began, aiming to reconstruct and simulate aspects of brain circuitry. Its goals should be distinguished from a demonstrated complete simulation of the human brain. |
| 2006 | The Dartmouth Artificial Intelligence Conference: The Next 50 Years (AI@50) AI@50 (14–16 July 2006) |
| 2007 | Philosophical Transactions of the Royal Society, B – Biology, one of the world's oldest scientific journals, puts out a special issue on using AI to understand biological intelligence, titled Models of Natural Action Selection |
| 2007 | Checkers is solved by a team of researchers at the University of Alberta. |
| 2007 | DARPA launches the Urban Challenge for autonomous cars to obey traffic rules and operate in an urban environment. |
| 2008 | Cynthia Mason at Stanford presents her idea on Artificial Compassionate Intelligence, in her paper on "Giving Robots Compassion". |
| 2009 | LSTM networks trained with connectionist temporal classification achieved strong results in handwriting-recognition competitions. |
| 2009 | Google builds autonomous car. |
| 2010 | Microsoft launched Kinect for Xbox 360, using depth sensing and machine learning to track users’ body movements for interaction. |
| 2011 | Mary Lou Maher and Doug Fisher organize the First AAAI Workshop on AI and Sustainability. |
| 2011 | IBM's Watson computer defeated television game show Jeopardy! champions Rutter and Jennings. |
| 2011–2014 | Apple's Siri (2011), Google's Google Now (2012) and Microsoft's Cortana (2014) are smartphone apps that use natural language to answer questions, make recommendations and perform actions. |
| 2010s | Neural attention mechanisms developed in sequence modelling, providing part of the foundation for the Transformer architecture introduced in 2017. |
| 2013 | Team SCHAFT led the DARPA Robotics Challenge Trials with 27 of 32 available points across eight disaster-response tasks. The robot should not be identified as HRP-2. DARPA trial results. |
| 2013 | NEIL, the Never Ending Image Learner, is released at Carnegie Mellon University to constantly compare and analyze relationships between different images. |
| 2015 | Rupesh Kumar Srivastava, Klaus Greff and Jürgen Schmidhuber introduced Highway Networks. Kaiming He, Xiangyu Zhang, Shaoqing Ren and Jian Sun introduced residual learning, with strong results in the ImageNet competition. These are distinct approaches to training deep networks; simple priority or citation-count claims do not explain their relationship. Residual learning paper. |
| 2015 | Researchers and public figures signed an open letter calling for a ban on offensive autonomous weapons beyond meaningful human control. |
| 2015 | Google DeepMind's AlphaGo (version: Fan) defeated three-time European Go champion 2 dan professional Fan Hui by 5 games to 0. |
| 2016 | DeepMind’s AlphaGo defeated Lee Sedol by four games to one in a widely followed Go match. |
| 2016 | Marijn Heule, Oliver Kullmann and Victor Marek reported a computer-assisted solution to the Boolean Pythagorean triples problem, using SAT solving and proof verification. Authors’ paper. |
| 2017 | Asilomar Conference on Beneficial AI was held, to discuss AI ethics and how to bring about beneficial AI while avoiding the existential risk from artificial general intelligence. |
| 2017 | DeepStack and Libratus demonstrated strong performance against professional players in heads-up no-limit poker. Poker introduces hidden information, making the evaluation different from games such as chess and Go. |
| 2017 | In May 2017, Google DeepMind's AlphaGo (version: Master) beat Ke Jie, who at the time continuously held the world No. 1 ranking for two years, winning each game in a three-game match during the Future of Go Summit. |
| 2017 | An OpenAI-machined learned bot played at The International 2017 Dota 2 tournament in August 2017. It won during a 1v1 demonstration game against professional Dota 2 player Dendi |
| 2017 | Google Lens image analysis and comparison tool released in October 2017, associates millions of landscapes, artworks, products and species to their text description. |
| 2017 | DeepMind introduced AlphaGo Zero, trained through reinforcement learning from self-play rather than a dataset of human moves. It defeated an earlier AlphaGo version in the reported evaluation. The related AlphaZero work extended self-play learning to chess and shogi as well as Go. These were results in defined games, not demonstrations of unrestricted general intelligence. Research announcement. |
| 2017 | Vaswani and colleagues introduced the Transformer architecture in Attention Is All You Need. The architecture became a foundation for later language models, including BERT and generative pretrained models. Transformer paper. |
| 2018 | Machine reading systems achieved prominent results on the Stanford Question Answering Dataset. Scores on this constrained benchmark should be distinguished from general human reading comprehension. |
| 2018 | The European Lab for Learning and Intelligent Systems (aka Ellis) proposed as a pan-European competitor to American AI efforts, with the aim of staving off a brain drain of talent, along the lines of CERN after World War II. |
| 2018 | Google demonstrated Duplex, a system for selected telephone interactions such as appointment booking. The demonstration prompted discussion of capability, disclosure and the limits of automated conversation. |
| 2019 | DeepMind reported that AlphaStar reached Grandmaster level in StarCraft II under the evaluation conditions of the study. |
| 2020 | Microsoft introduced Turing Natural Language Generation (T-NLG), part of the period’s rapid growth in language-model scale. |
| 2020 | In November 2020, AlphaFold 2 by DeepMind, a model that performs predictions of protein structure, won the CASP competition. |
| 2020 | OpenAI introduced GPT-3 in Language Models are Few-Shot Learners. The paper evaluated a 175-billion-parameter autoregressive model across multiple tasks, reporting both capabilities and limitations. These task-specific findings do not establish that all outputs are indistinguishable from human writing. GPT-3 paper. |
| 2022 | OpenAI released ChatGPT as a research preview in November 2022. Its conversational interface attracted broad public attention, while its release documentation described limitations including plausible-sounding but incorrect answers. Release announcement. |
| 2023 | Public adoption of conversational AI became a prominent topic of discussion. Reported usage estimates depend on the source and measurement period; they should not be treated as an audited count of active users without that context. |
| 2023 | OpenAI introduced GPT-4 in March 2023 as a multimodal model accepting text and image inputs. Its technical report described benchmark performance and remaining limitations. Exam results were model evaluations under specified conditions, not proof of professional competence or general intelligence. Technical report. |
| 2023 | Google opened limited access to Bard in March 2023, initially describing it as powered by a lightweight optimized version of LaMDA. Later model changes should be distinguished from that launch configuration. Launch announcement. |


